Language models had the internet. Robots have almost nothing.
Physical intelligence is bottlenecked by data, not architecture. Robot learning needs enormous quantities of high-quality real-world interaction — captured with human dexterity, at human scale, in unconstrained environments.
Text corpora
Trillions of tokens
Scraped, cheap, effectively unlimited.
Robot data
Orders of magnitude short
Teleoperation is slow, costly and lab-bound.
Human motion
Continuous, everywhere
Every hand, every day — currently uncaptured.
Our system
Wearable hardware that turns a person into a capture rig.
A coordinated set of worn sensors records motion and interaction while the wearer simply goes about real tasks.
Head-mounted
Egocentric vision and head pose. What the hands do, seen the way a robot will see it.
Tracking gloves
Finger articulation and hand pose at fidelity sufficient for dexterous manipulation.
Wearable cuffs
Arms, legs and torso. Lightweight sensing that disappears into ordinary clothing.
Mobile capture
No studio, no markers, no volume. Data collection wherever work already happens.
From humans to robots
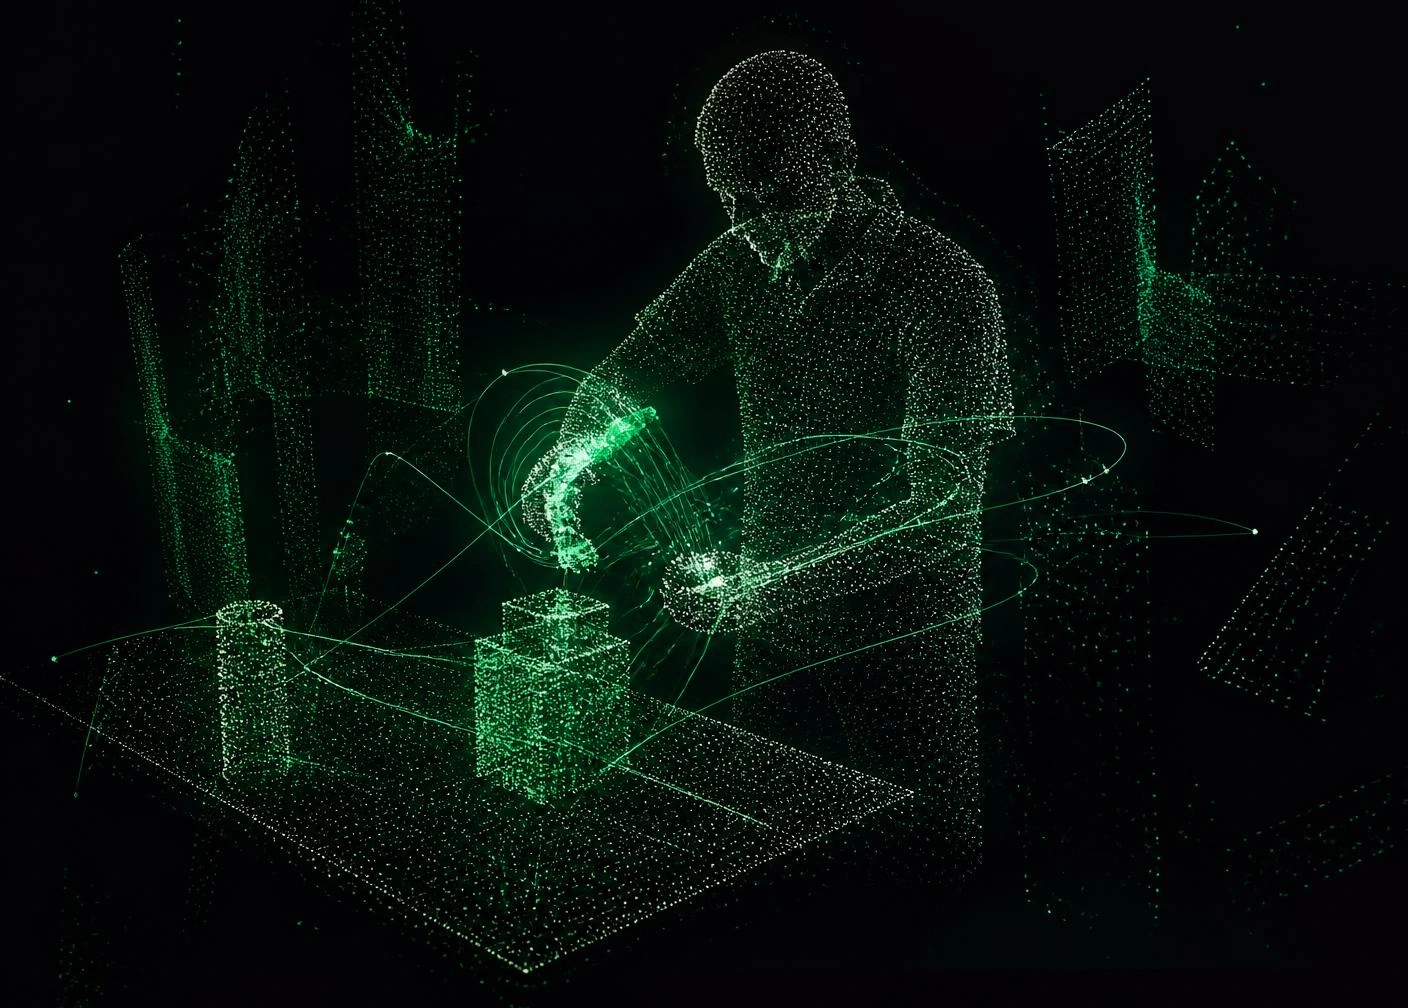
Human movement → structured motion data → robot training.
01. Human
A person performs an ordinary real-world task.
02. Tracked skeleton
Joints, fingers and 6-DoF trajectories are resolved in real time.